
Industries
Construction, Agriculture &
Mining: Physical ai Integration
Rugged perception, autonomy, and equipment intelligence for demanding off-road operations
By Ceri Nelmes
Tech Marketing Leader & Journalist | Building Brands at the Edge of What’s Next | Connect Tech & CTai Labs
Technical review: Rob Callaghan, Chief Product Officer, Connect Tech Inc.

Key Takeaways
- CTai LABS integrates Physical ai for construction, agriculture, and mining from cameras and sensors through perception, fusion, application logic, equipment interfaces, validation, and deployment
- Work can begin with an idea, an operating goal, an existing machine, a sensor package, a dataset, a trained model, a research prototype, a stalled integration, or a production software baseline
- Construction, farming, and mining share harsh environmental and equipment-integration challenges, but each program requires its own operating domain, evidence, workflow, and acceptance criteria
- Connect Tech rugged systems, vehicle platforms, carrier boards, and camera platforms provide deployment paths for NVIDIA® Jetson Orin™ and NVIDIA Jetson Thor™ workloads
- Safety, authority, regulatory, environmental, and operational decisions remain with the customer and its qualified engineering, safety, compliance, and operations teams
CTai LABS, a department of Connect Tech, helps equipment manufacturers, technology providers, contractors, growers, mining operators, and industrial teams turn a Physical ai objective into a rugged, measurable, deployment-ready system. This page explains how CTai LABS integrates cameras, LiDAR, radar, GNSS, inertial sensors, machine networks, and condition data with NVIDIA accelerated computing, perception, sensor fusion, autonomy software, equipment interfaces, validation, and production-ready Connect Tech hardware. CTai LABS can start with only an idea and the outcome the machine or site must achieve, or join at any later point to select hardware, bring up sensors, integrate an existing model, port software, resolve a performance problem, validate a prototype, or prepare a controlled field deployment.
Bring Physical ai to the worksite, field, and mine
Construction, agriculture, and mining operate where perception is difficult and failures matter. Dust can obscure a camera. Glare, darkness, rain, snow, fog, vibration, mud, crop canopy, changing terrain, reflective material, and equipment motion can alter the evidence available to the system. Connectivity may be intermittent, power and thermal headroom may be limited, and the ai workload must coexist with recording, communications, diagnostics, and machine-control interfaces on the same Edge platform.
CTai LABS treats these conditions as architecture inputs rather than exceptions discovered after a demonstration. The engagement begins with the operating goal, the people and equipment involved, the allowed authority, the environment, and the evidence required to release the next stage. The result may be an operator-assistance function, a perception subsystem, an inspection tool, a condition-monitoring node, a semi-autonomous machine capability, or a broader Physical ai platform. In every case, the sensing, compute, software, machine interface, human workflow, and validation plan are engineered as one system.
Recent peer-reviewed research supports this systems approach. Rabbi and Jeelani (2024) found that construction safety ai spans text, vision, and audio applications, while real-world adoption continues to face data, generalization, privacy, and integration challenges. Ghazal, Munir, and Qureshi (2024) describe agricultural computer vision across image acquisition, analysis, decision-making, treatment, and planning, and highlight the difficulty of generalizing models into real-time autonomous farming. Codoceo-Contreras, Rybak, and Hassall (2024) identify interoperability, wireless networks, human factors, trust, and organizational change as central concerns in mining automation. These findings point to the same deployment principle: the full sensor-to-action path must be measured in the intended operating environment.
Examples: one integration discipline, three distinct operating environments
| Industry | Representative Physical ai workloads | Critical integration questions |
|---|---|---|
| Construction | Worker and equipment awareness, exclusion zones, progress capture, material recognition, grading or machine guidance, remote inspection, and fleet condition monitoring. | Can the system preserve coverage and timing as the site changes? How are alerts, operator authority, privacy, and equipment interfaces bounded? |
| Agriculture | Crop and weed perception, precision application, autonomous implement functions, yield and quality sensing, livestock monitoring, navigation, and equipment health. | Will perception generalize across crop stage, cultivar, soil, lighting, weather, speed, and season? Can the function operate when connectivity is limited? |
| Mining | Haulage and mobile-equipment perception, collision-risk awareness, fragmentation and material analysis, inspection, environmental sensing, autonomous functions, and predictive maintenance. | How are dust, darkness, scale, communications loss, interoperability, human factors, degraded modes, and operational authority managed? |
Where heavy-industry ai programs stall
The operating goal is described as a model task
Object detection, segmentation, anomaly detection, localization, forecasting, and planning are technical methods, not operating outcomes. CTai LABS translates the desired result into a bounded function: what the system must observe, what output it creates, who or what consumes it, how quickly it matters, where a person remains responsible, what happens when confidence falls, and which evidence will determine readiness.
Sensor selection ignores the actual evidence conditions
A camera or LiDAR specification does not prove that the source can support the task. Mounting height, lens and field of view, target range, motion, vibration, occlusion, dust, mud, crop canopy, low texture, illumination, weather, cleaning, connector exposure, and maintenance access all affect usable evidence. CTai LABS builds an evidence budget for cameras, radar, LiDAR, GNSS, inertial sensors, encoders, machine networks, and condition sensors, then measures calibration, synchronization, source health, loss, and degradation.
The ai model is separated from machine context
A useful system often needs more than an image prediction. Vehicle state, implement position, machine speed, hydraulic or engine data, GNSS quality, inertial motion, map context, route state, and operator mode can change the meaning of the same detection. CTai LABS integrates perception with approved CAN, Ethernet, serial, ROS 2, positioning, timing, and application interfaces so outputs are contextual, traceable, and bounded by the current machine state.

A successful bench test is treated as field validation
Recorded data and laboratory replay are necessary, but they do not reproduce every timing, thermal, power, vibration, contamination, network, sensor-health, and operator interaction found in the field. CTai LABS uses a staged evidence path that can include simulation, recorded replay, software-in-the-loop, hardware-in-the-loop, controlled site trials, shadow operation, and monitored rollout. Each stage has explicit entry criteria, scenarios, metrics, results, known limits, and ownership.
The deployment platform is chosen after the software
Camera ingest, decoding, point-cloud processing, model inference, localization, fusion, mapping, recording, cybersecurity controls, communications, logging, and updates compete for memory bandwidth, compute, storage, power, and thermal capacity. CTai LABS profiles the complete workload on the intended Connect Tech platform and NVIDIA® Jetson™ module, then sizes headroom for sustained operation and future change rather than relying on peak accelerator specifications.
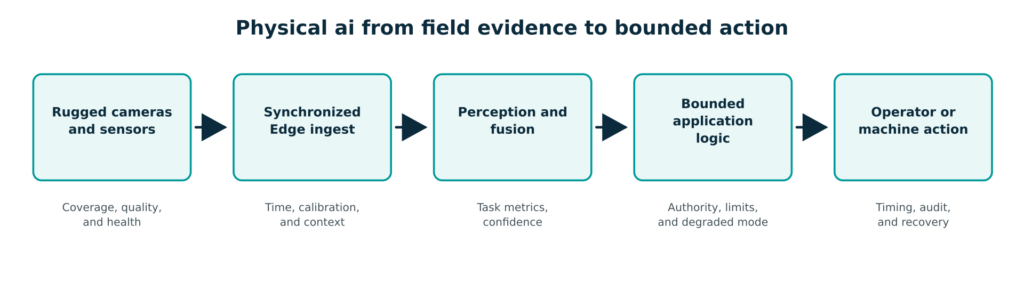
Figure 1. Construction, agriculture, and mining applications create value across the complete path from rugged sensing to a bounded operator or machine response.
Architecture Through Deployment
CTai LABS can lead the complete integration or focus on the earliest high-risk boundary in an existing program. Components that already satisfy the requirement can remain in place. Missing requirements, datasets, sensor specifications, interfaces, models, and acceptance criteria can be developed as part of the engagement.
- Define the operating outcome, users, equipment, operating domain, worksite or field conditions, authority boundary, response time, degraded behavior, data policy, risks, and acceptance evidence.
- Select Connect Tech hardware, NVIDIA Jetson Orin™ or Jetson Thor™ compute, cameras and sensors, storage, networking, machine interfaces, input power, thermal design, enclosure, connectors, mounting, and service requirements.
- Bring up the Board Support Package (BSP), devices, clocks, calibration, transforms, recording, replay, source-health monitoring, CAN or equipment data, observability, cybersecurity controls, update, and recovery.
- Integrate CUDA®, TensorRT™, approved NVIDIA Isaac™ or NVIDIA Metropolis components, ROS 2, perception, localization, mapping, fusion, condition analytics, event logic, human-machine interfaces, and equipment or enterprise systems where they fit the approved function.
- Optimize models, preprocessing, memory movement, scheduling, concurrency, and pipelines against task equivalence, latency distribution, throughput, resource use, power, thermals, and sustained operation on target hardware.
- Validate with representative seasons, terrain, materials, lighting, weather, dust, vibration, speed, communications loss, sensor degradation, operator workflows, restart, update, and long-duration scenarios.
- Deliver the controlled CTI EdgeAI Stack software baseline, model and configuration lineage, interface documentation, test evidence, known limits, deployment procedure, lifecycle plan, and engineering handoff.
Choose where the intelligence should run
Compute placement follows sensor bandwidth, response time, machine mobility, connectivity, environmental exposure, service access, and the authority of the function. A compact implement controller, a vehicle perception computer, and a fixed multi-camera processing node solve different problems even when they use similar models. CTai LABS evaluates the complete fleet and site architecture before standardizing hardware.
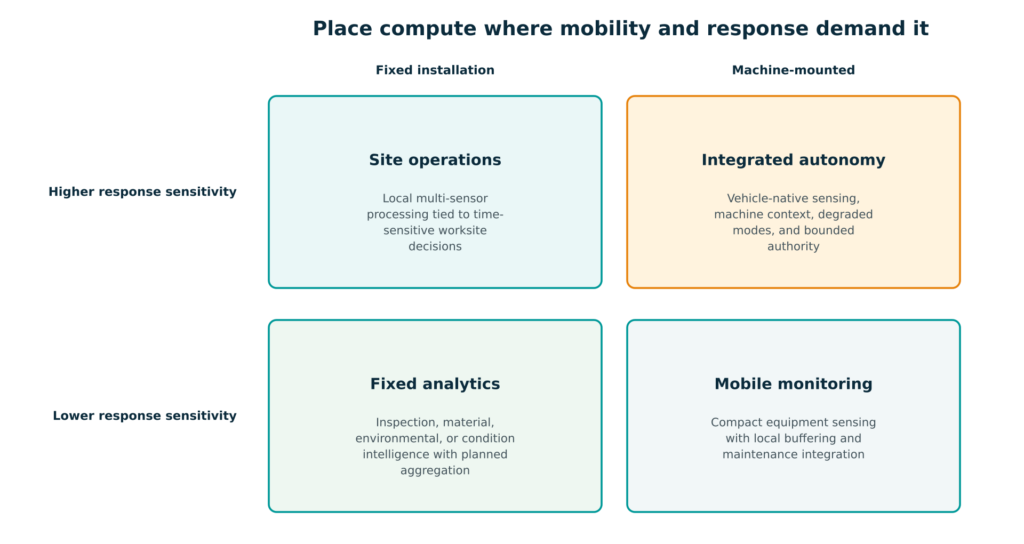
Figure 2. Mobility and response sensitivity help determine whether the workload belongs on a fixed site node, a mobile monitoring unit, a vehicle Edge platform, or a tightly integrated autonomy computer.
Connect Tech hardware for construction, agriculture, and mining
Connect Tech hardware is part of the integration decision because ruggedization, cameras, vehicle networking, storage, input power, connectors, cooling, and Board Support Package behavior determine what the Physical ai stack can sustain. CTai LABS maps each workload to the smallest platform that meets the measured operating envelope with appropriate headroom, then validates the complete configuration rather than treating the module alone as the system.
| Connect Tech platform | Best fit | Architecture value |
|---|---|---|
| Falcon Vehicle System with NVIDIA Jetson Orin NX™ | Compact machine-mounted perception and operator-assistance functions | IP67, fanless vehicle compute with GMSL2 camera inputs, automotive Ethernet, CAN FD, GNSS, and wireless expansion for harsh mobile applications. |
| Anvil-RX with NVIDIA Jetson AGX Orin™ | Rugged multi-sensor equipment, field, and site deployments | IP67 system with sealed connectors and higher compute capacity for concurrent perception, fusion, recording, communications, and application workloads. |
| GMSL2 Plus or GMSL3 Camera Platform | Multi-view equipment perception and remote camera placement | Supports up to eight compatible cameras on supported Jetson AGX Orin and Jetson Thor platforms, with data, control, and power over a single coaxial path. |
| Anvil-T5 with NVIDIA Jetson Thor | Sensor-rich autonomy and advanced multimodal Physical ai | Rugged Jetson Thor system with high-bandwidth networking and vision expansion for demanding workloads after power, thermal, software, and lifecycle needs are verified. |
Example construction, agriculture, and mining projects
The following spoke pages are in development for a future phase. Each covers one defense ai integration topic in technical depth.
Construction equipment awareness and exclusion-zone support
An equipment manufacturer needs local perception around a loader or excavator to identify people, vehicles, obstacles, and defined work zones without depending on continuous cloud connectivity. CTai LABS defines the operating domain and alert boundary, integrates rugged cameras and machine state on Falcon or Anvil-RX, optimizes the approved models, connects outputs to the operator interface, and validates range, occlusion, dust, lighting, motion, sensor loss, nuisance alerts, timing, restart, and long-duration operation. The customer and its qualified safety and machine-control teams retain authority over the safety concept and equipment response.
Precision agriculture perception and implement intelligence
An agricultural technology provider needs row, crop, weed, or fruit perception to guide an implement function across changing varieties, growth stages, soil, illumination, speed, and weather. CTai LABS builds the camera and positioning path, creates synchronized recording and replay, integrates the model and application on Connect Tech rugged hardware, profiles throughput and latency, and establishes a seasonal dataset and validation plan. Work can begin with raw field video, an existing model, a machine interface, or only the desired agronomic outcome.
Cross-fleet condition and predictive-maintenance node
A fleet operator needs local analysis of vibration, temperature, pressure, acoustics, images, and machine-network data across equipment with different ages and duty cycles. CTai LABS defines asset states and maintenance decisions, integrates sensors and equipment data, develops or ports the approved anomaly or forecasting pipeline, establishes local buffering and store-and-forward behavior, and connects results to the maintenance workflow. Validation distinguishes normal duty-cycle variation from actionable change and documents data gaps, uncertainty, and known limits.

Mining mobile-equipment perception and operational integration
A mining technology program needs perception and sensor fusion on mobile equipment operating through dust, darkness, vibration, changing terrain, intermittent networks, and mixed human-machine traffic. CTai LABS integrates cameras, LiDAR, radar, GNSS, inertial sensing, and approved machine data; builds source-health and degraded-mode behavior; deploys the workload on Anvil-RX or Anvil-T5; and validates replay, hardware-in-the-loop, communications loss, timing, environmental conditions, operator workload, and controlled site scenarios before a broader rollout.
What CTai LABS can deliver
- Operating-domain and use-case definition, users, authority boundaries, human-machine workflow, requirements, risk register, degraded behavior, and acceptance matrix.
- Camera and sensor plan, evidence budget, calibration and timing architecture, Connect Tech platform and NVIDIA Jetson module selection, power, thermal, enclosure, connector, storage, networking, and service requirements.
- BSP and driver baseline, CAN and equipment interfaces, device bring-up, recording and replay, source health, observability, cybersecurity controls, update, recovery, and diagnostic tooling.
- Integrated perception, fusion, localization, condition analytics, ROS 2 or application software, NVIDIA accelerated pipelines, operator interfaces, and approved equipment or enterprise integrations.
- Representative dataset and scenario suite, task metrics, latency and throughput traces, sustained-load results, environmental and communications-loss evidence, failure analysis, and known operating limits.
- Versioned CTI EdgeAI Stack release, software and model lineage, deployment image, configuration, interface and build documentation, rollout plan, lifecycle recommendations, and knowledge transfer.
Your Physical ai Integration Partner
CTai LABS combines production-ready Connect Tech hardware, in-house Board Support Package engineering, rugged camera and sensor integration, ROS 2 and autonomy software, NVIDIA accelerated computing, ai model optimization, machine and operational interfaces, and field-representative validation in one Physical ai program. The team can begin with an idea, contribute at one difficult boundary, recover a stalled integration, or carry the complete approved system from architecture through deployment while the customer retains its intellectual property and owns its safety, regulatory, environmental, and operational decisions.
ABOUT THE AUTHOR
Ceri Nelmes
Tech Marketing Leader & Journalist | Building Brands at the Edge of What’s Next |
Connect Tech & CTai Labs
Ceri Nelmes is Head of Marketing at Connect Tech and an experienced technology journalist and digital strategist. She covers the technologies and market shifts shaping embedded computing, Edge AI, Physical ai, robotics, autonomous systems, and the NVIDIA® ecosystem. Working with Connect Tech and CTai LABS subject-matter experts, she turns engineering developments into accurate, useful reporting for developers, technical buyers, business leaders, and the media.
Book a Demo
Bring your goal. Start with the outcome your autonomous-vehicle program must achieve. CTai LABS, a department of Connect Tech, can begin with an early idea, an architecture decision, a working prototype, a difficult integration issue, or a system that must become deployment-ready.
What to bring:
- The vehicle function, operating design domain, speed and environment, human and system roles, controller boundary, fallback, and next evidence gate.
- Current or proposed cameras, radar, LiDAR, GNSS, IMU, vehicle networks, Connect Tech hardware, NVIDIA platform, storage, time source, power, enclosure, and cooling.
- ROS 2 or autonomy graph, algorithms, models, calibration, recorded data, maps, simulation assets, interface-control documents, logs, traces, and repeatable failure cases.
- Safety, cybersecurity, data, update, recovery, service, environmental, qualification, supplier, regulatory, and lifecycle requirements owned by the program.
- Scenario, task, latency, localization, fusion, sustained-load, degraded-mode, SIL/HIL, vehicle-test, release, and acceptance evidence required for the next milestone.
CTai LABS uses these inputs to identify the highest-risk interfaces first and define the shortest credible path to a working, measurable system.
 Learn More
Resources and Frequently Asked Questions
Continue into the CTai LABS services and technical capabilities that support rugged perception, equipment intelligence, and deployment-ready Physical ai.
Related
Rugged Edge ai. Edge ai architecture and validation for harsh industrial environments.
Explore Rugged Edge ai →Sensor Fusion. Time-aligned camera, LiDAR, radar, GNSS, inertial, and machine-state integration.
Explore Sensor Fusion →Robot Perception. Perception pipelines for mobile machines and changing operating environments.
Explore Robot Perception →Predictive Maintenance. Condition monitoring, anomaly detection, and maintenance-workflow integration.
Explore Predictive Maintenance →System & Sensor Integration. Cameras, sensors, timing, calibration, drivers, and the complete Edge data path.
Explore System & Sensor Integration →Sources
Badhan, S. J., & Samsami, R. (2025). Artificial intelligence (AI) in construction safety: A systematic literature review. Buildings, 15(22), 4084.
https://doi.org/10.3390/buildings15224084Codoceo-Contreras, L., Rybak, N., & Hassall, M. (2024). Exploring the impacts of automation in the mining industry: A systematic review using natural language processing. Mining Technology, 133(3).
https://doi.org/10.1177/25726668241270486Connect Tech. (n.d.). Anvil-RX rugged system powered by NVIDIA Jetson AGX Orin. Retrieved August 26, 2026, from
https://connecttech.com/product/anvil-rx-rugged-system-powered-by-nvidia-jetson-agx-orin/Connect Tech. (n.d.). Anvil-T5 Edge system with NVIDIA Jetson Thor. Retrieved August 26, 2026, from
https://connecttech.com/product/anvil-t5-edge-system-with-nvidia-jetson-thor/Connect Tech. (n.d.). Falcon vehicle system with NVIDIA Jetson Orin NX. Retrieved August 26, 2026, from
https://connecttech.com/product/falcon-vehicle-system-with-nvidia-jetson-orin-nx/Connect Tech. (n.d.). GMSL3 camera platform for NVIDIA Jetson AGX Orin and Jetson Thor. Retrieved August 26, 2026, from
https://connecttech.com/product/gmsl3-camera-platform-nvidia-jetson-agx-orin-jetson-thor/Ghazal, S., Munir, A., & Qureshi, W. S. (2024). Computer vision in smart agriculture and precision farming: Techniques and applications. Artificial Intelligence in Agriculture, 13, 64–83.
https://doi.org/10.1016/j.aiia.2024.06.004Miller, T., Mikiciuk, G., Durlik, I., Mikiciuk, M., Lobodzinska, A., & Snieg, M. (2025). The IoT and AI in agriculture: The time is now, a systematic review of smart sensing technologies. Sensors, 25(12), 3583.
https://doi.org/10.3390/s25123583Obosu, M., & Frimpong, S. (2025). Advances in automation and robotics: The state of the emerging future mining industry. Journal of Safety and Sustainability, 2(3), 181–194.
https://doi.org/10.1016/j.jsasus.2025.05.003Rabbi, A. B. K., & Jeelani, I. (2024). AI integration in construction safety: Current state, challenges, and future opportunities in text, vision, and audio based applications. Automation in Construction, 164, 105443.
https://doi.org/10.1016/j.autcon.2024.105443Frequently Asked Questions
Can CTai LABS start with only an idea?
Yes. CTai LABS can begin with the operating outcome, machine or site context, users, authority boundary, constraints, and desired milestone, then define the sensors, Connect Tech hardware, software, integration, validation, and deployment path.
Can CTai LABS join an existing construction, agriculture, or mining program?
Yes. The team can assess an existing sensor package, dataset, model, NVIDIA Jetson system, ROS 2 stack, prototype, machine interface, or production baseline and focus on the earliest technical risk without replacing components that already meet the requirement.
Can the system operate without reliable cloud connectivity?
Many workloads can process locally and buffer selected evidence at the Edge. The correct design depends on response time, bandwidth, storage, update, monitoring, and operational requirements. CTai LABS defines and tests disconnected, degraded, and recovery behavior for the approved function.
Which Connect Tech platform is best for heavy equipment?
Falcon is a compact IP67 vehicle platform for NVIDIA Jetson Orin NX with GMSL2, automotive Ethernet, CAN FD, GNSS, and wireless options. Anvil-RX provides greater Jetson AGX Orin capacity for demanding rugged workloads. The final selection follows measured sensors, interfaces, compute, memory, storage, power, thermal, mechanical, and lifecycle requirements.
Does CTai LABS support multi-camera and sensor-fusion systems?
Yes. CTai LABS can integrate compatible GMSL cameras, LiDAR, radar, GNSS, inertial sensors, encoders, CAN and other approved data sources, including calibration, timestamping, transforms, recording, replay, fusion, source health, and degraded behavior.
How does CTai LABS validate Physical ai in harsh environments?
Validation can combine simulation, representative recorded data, replay, software-in-the-loop, hardware-in-the-loop, environmental and sustained-load testing, shadow operation, and monitored rollout. The exact path follows the operating domain, function, authority, risk, and evidence required by the customer.
Does CTai LABS certify equipment safety or regulatory compliance?
Validation can combine simulation, representative recorded data, replay, software-in-the-loop, hardware-in-the-loop, environmental and sustained-load testing, shadow operation, and monitored rollout. The exact path follows the operating domain, function, authority, risk, and evidence required by the customer.
Who owns the data and intellectual property?
The customer retains its field and machine data, models, algorithms, application, system design, and intellectual property. Engagement deliverables, third-party components, and licensing boundaries are defined in the statement of work.
Ready to Build Smarter?
Let’s create the intelligent Edge AI solution that moves your business forward.